Choose
Select your G-Lab Bot color and collect every component with a Tech Leader.
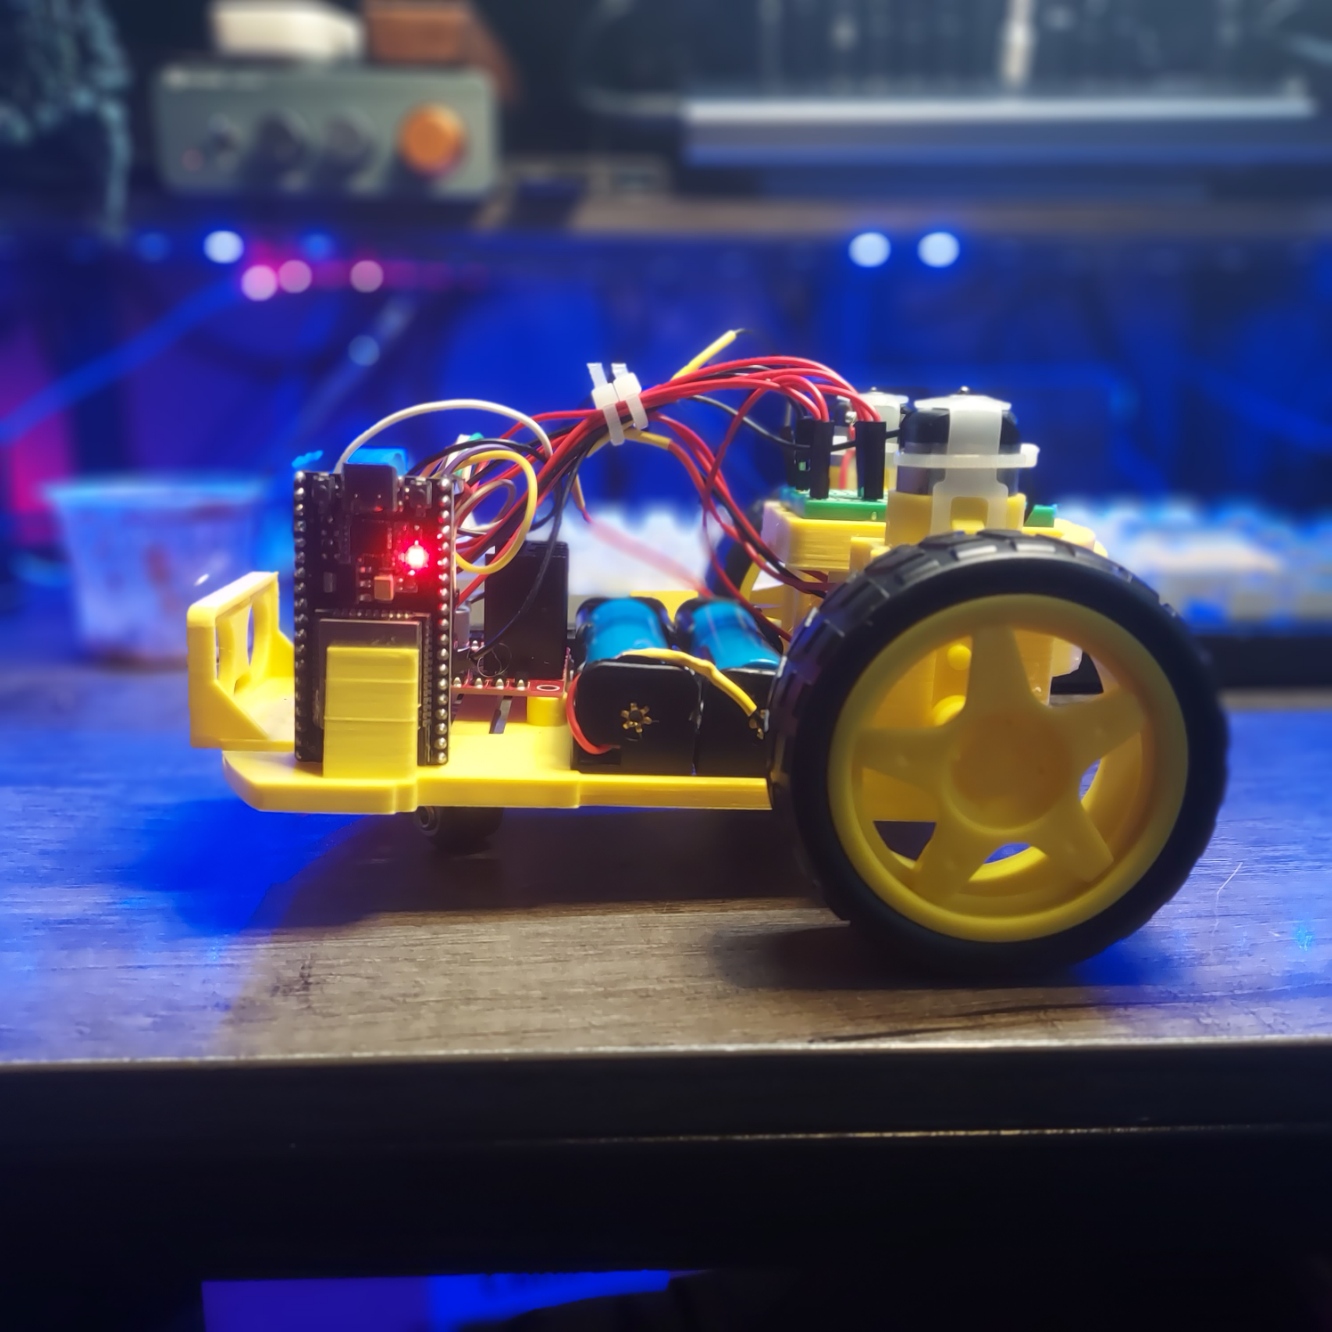
Your challenge is to turn a colorful G-Lab Bot chassis into a working Bluetooth-controlled robot powered by an ESP32. You will assemble the hardware, create safe power rails, upload a sketch, and drive with the Dabble Gamepad.
Engineering is teamwork. You will make many of the connections yourself, while a Genius Lab Tech Leader assists with the Heat Station, battery tests, electrical checks, and troubleshooting.
Select your G-Lab Bot color and collect every component with a Tech Leader.
Install the switch, battery holder, breadboard, caster, motors, and L298N Motor Driver.
Create 7.4V, ground, and 5V rails; connect the ESP32; and verify the circuit safely.
Prepare Arduino IDE, upload the sketch, connect Dabble, and take control.
A microcontroller is a tiny programmable computer. The ESP32 reads your commands, runs the sketch, and sends control signals to the L298N Motor Driver.
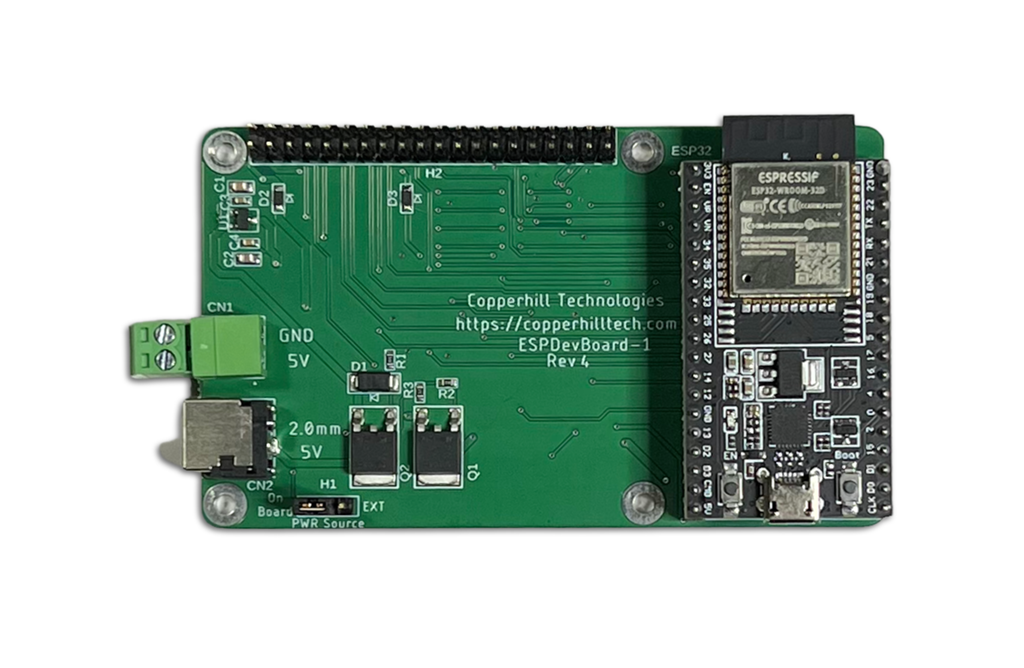
ESP32 Development Board — handle it by the edges.
Select one available G-Lab Bot chassis. Ask a Tech Leader which colors are ready at the storage rack.
Bring your selected chassis to the rack. Check off each item before assembly and handle every electronic component with care.
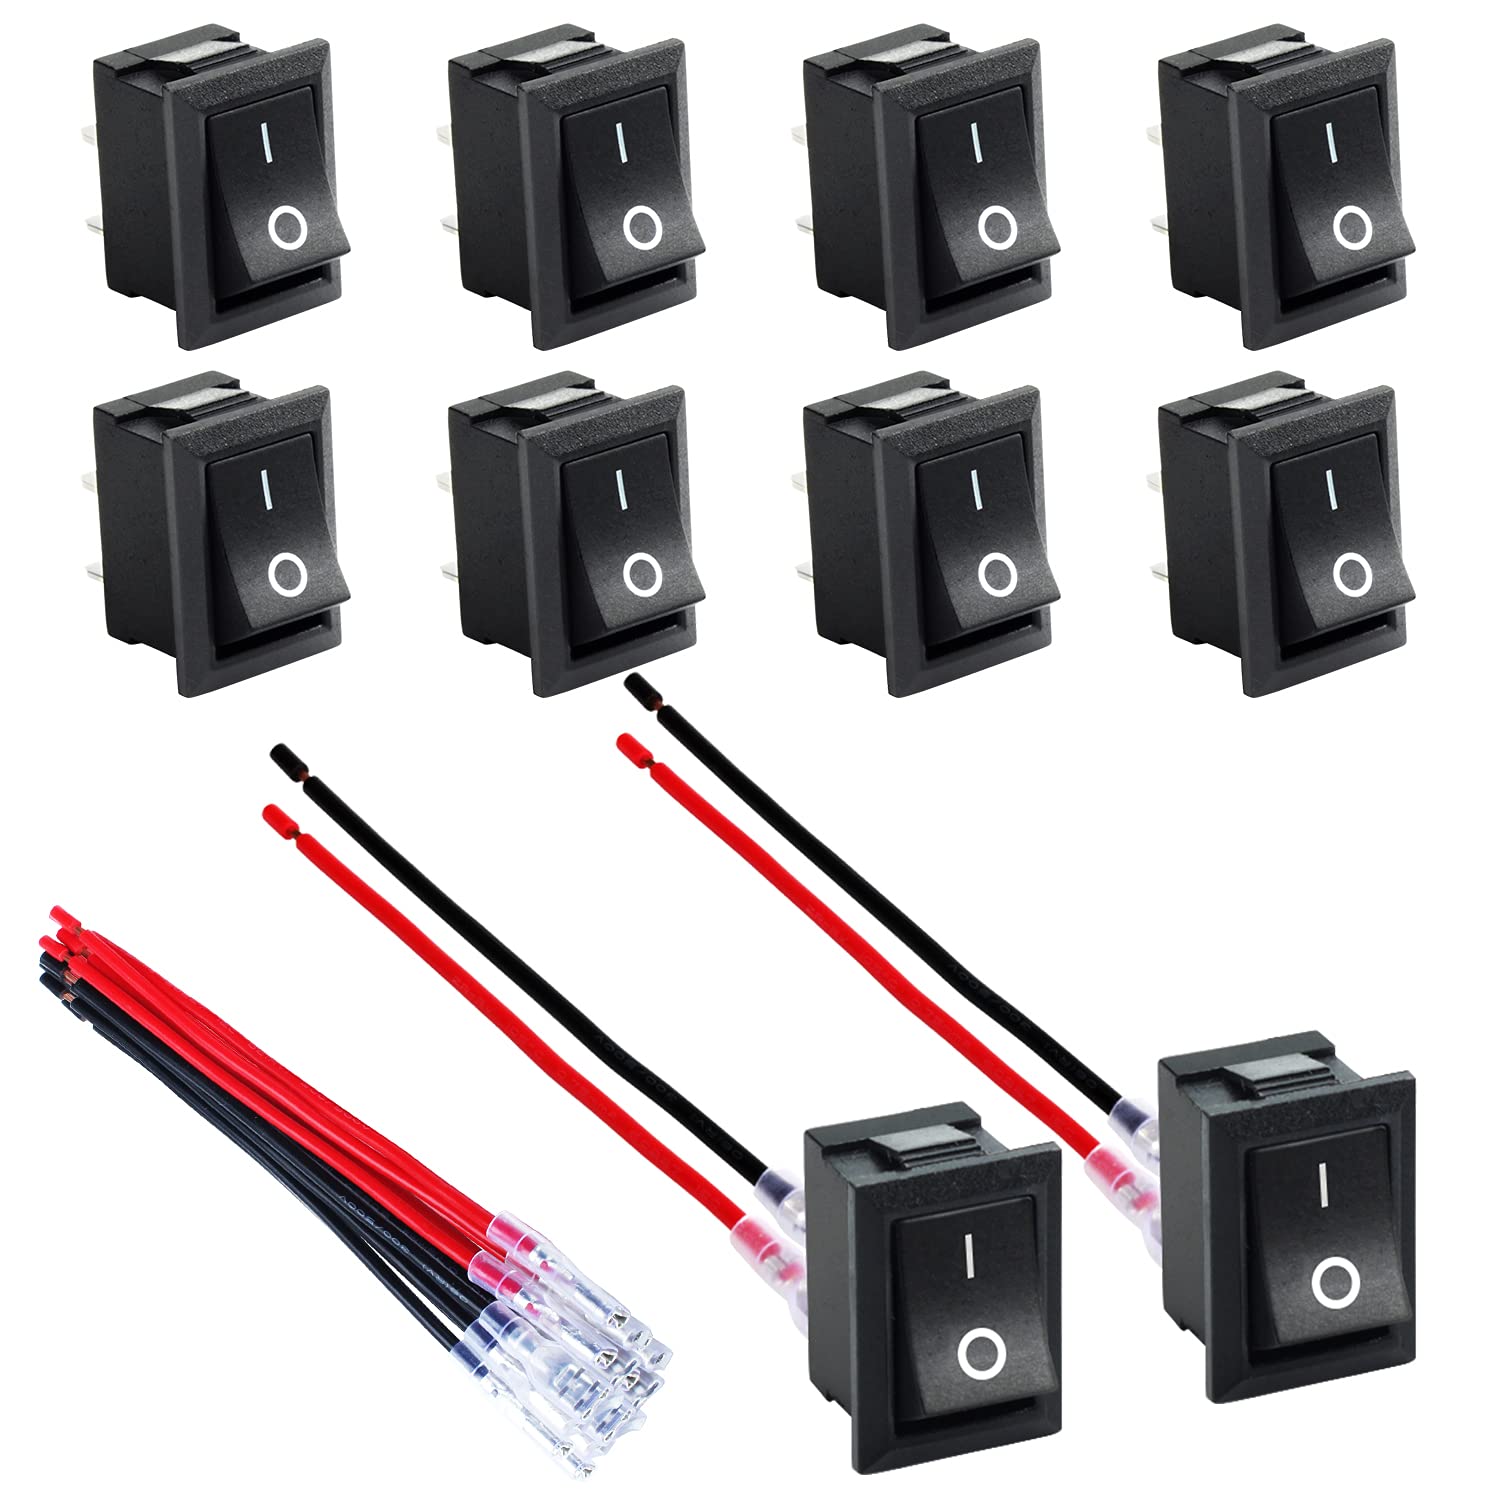
Master ON/OFF control installed in the rear slot of the Bot.
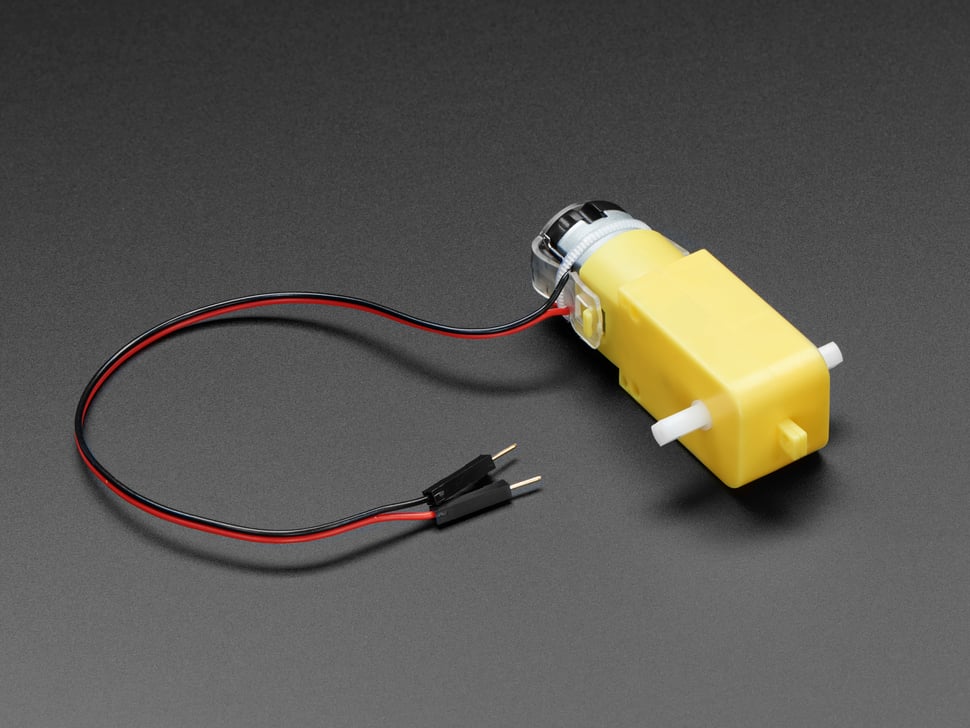
Slide into the designated motor slots and drive the two wheels.
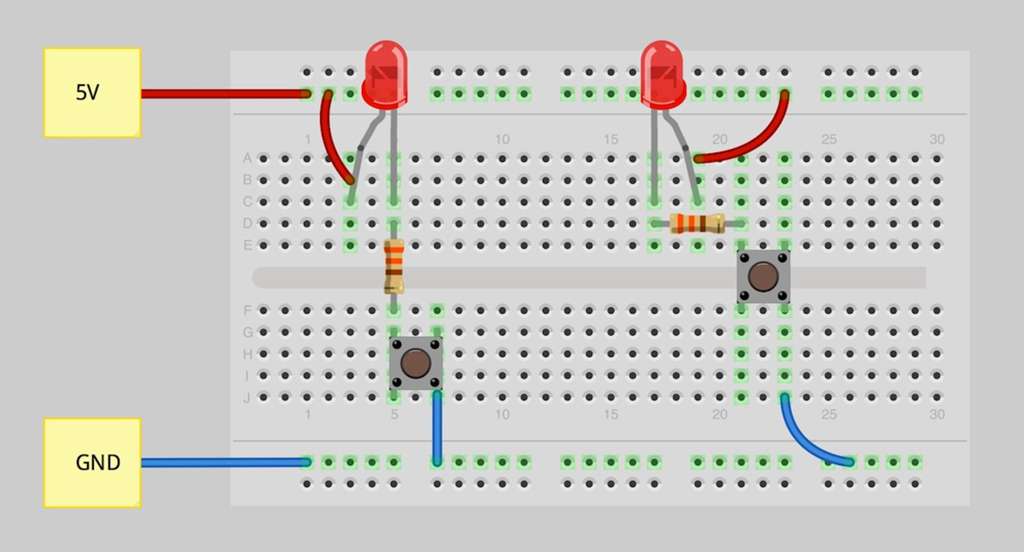
Distributes 7.4V, 5V, and ground without soldering.
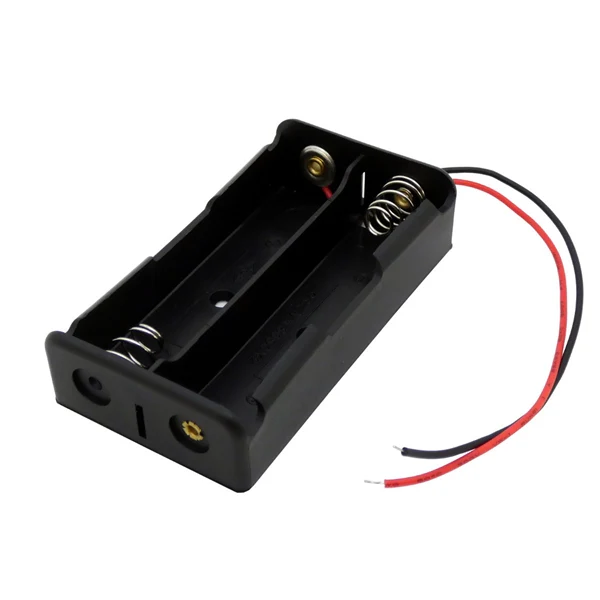
Holds two 3.7V cells in series for approximately 7.4V.
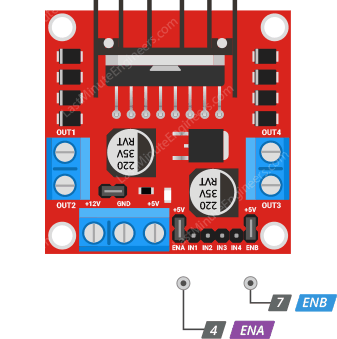
Directs battery power to both motors under ESP32 control.
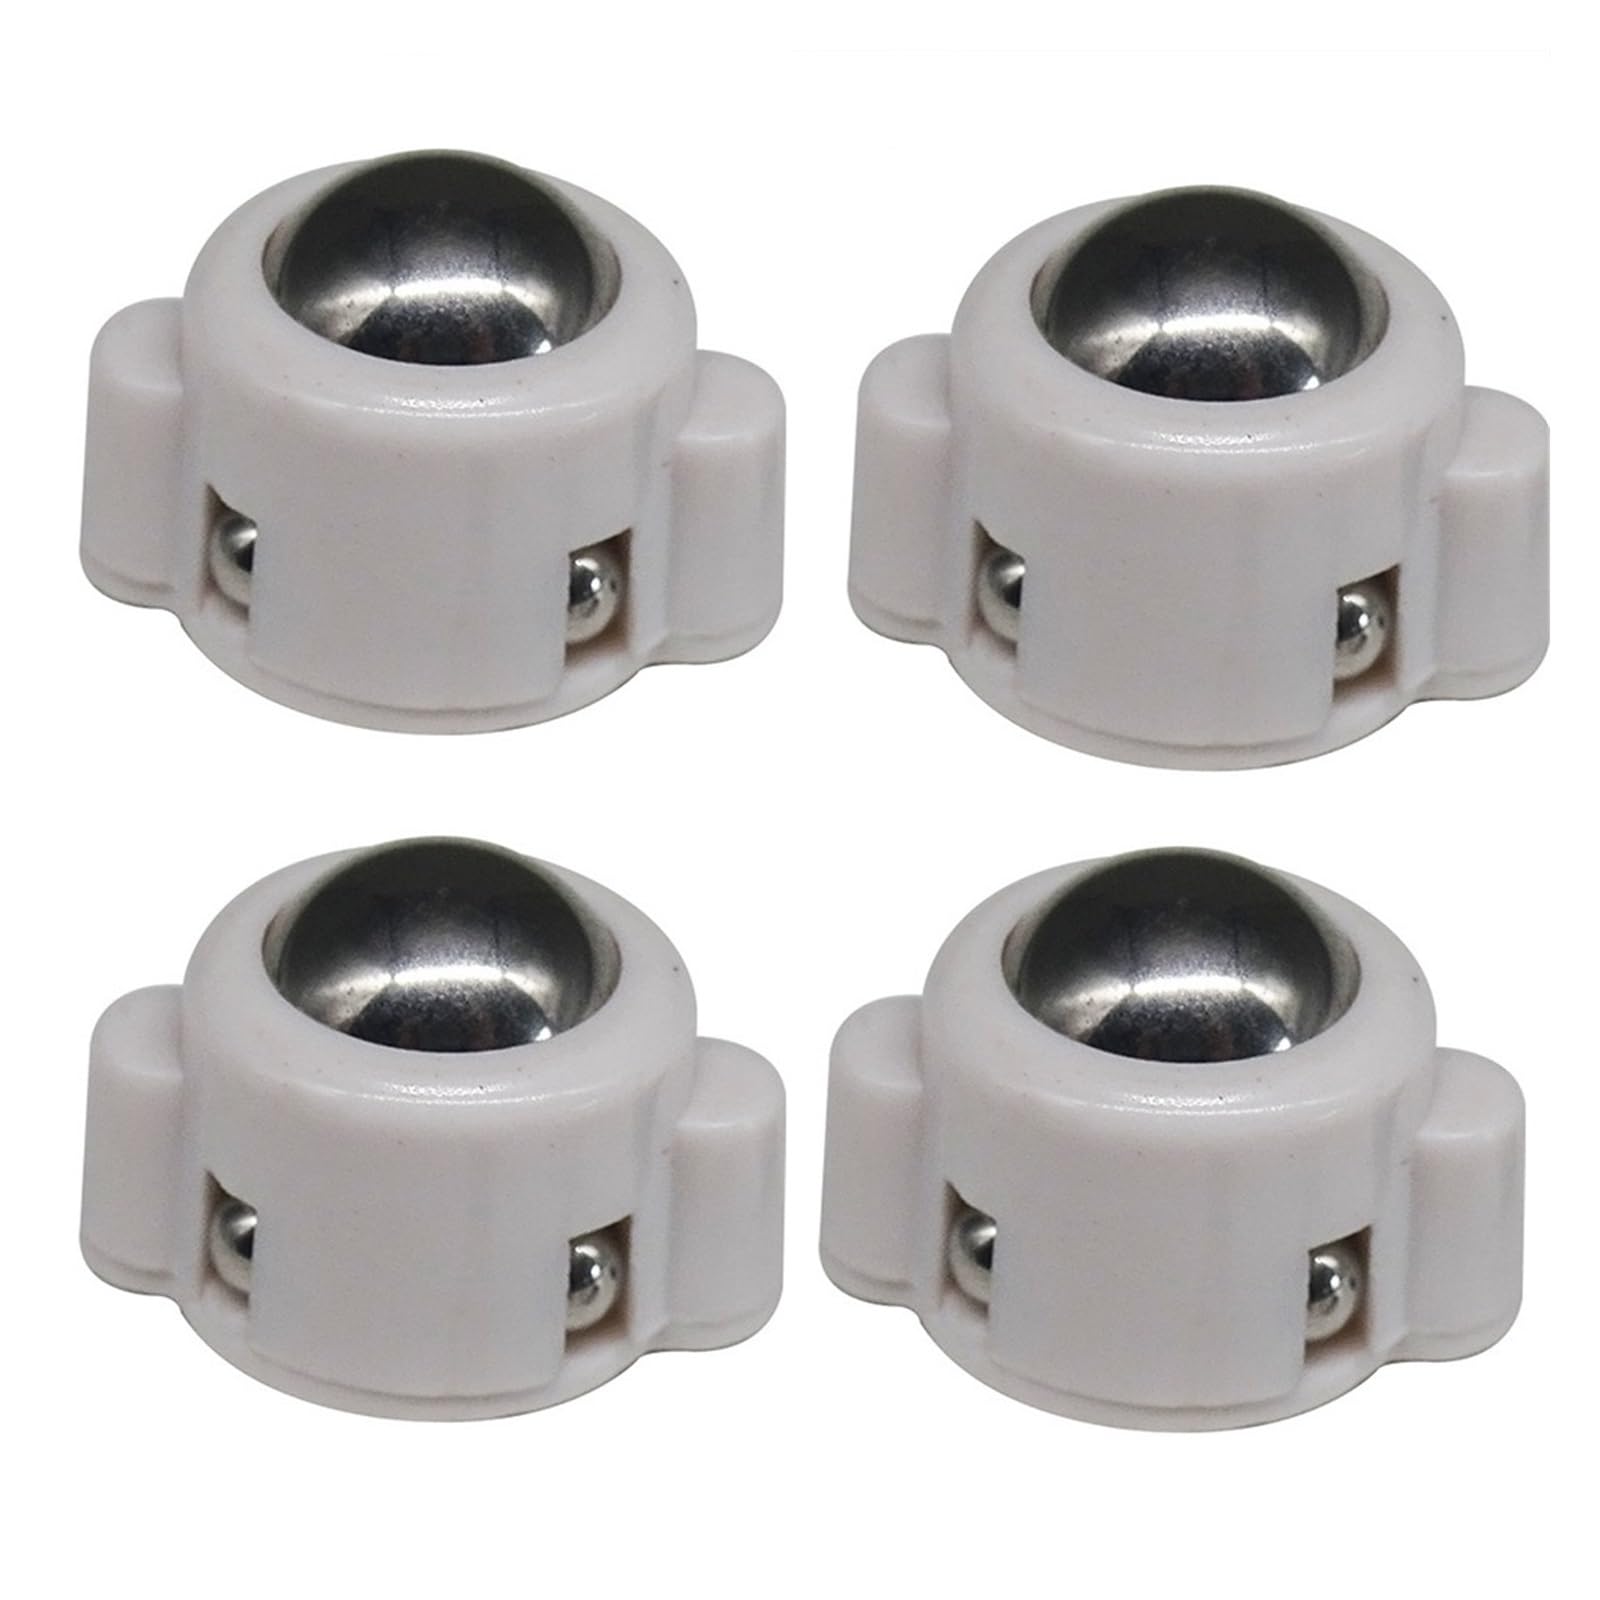
Supports and balances the front or rear of the two-wheel Bot.
“Male” means a metal pin sticks out. “Female” means the end has a socket. Match the connector to the component.
Metal pins on both ends. Use for breadboard-to-breadboard connections and for the battery ground lead prepared at the Heat Station.
Sockets on both ends. Use when both components already have exposed pins, such as ESP32 GPIO headers and L298N control pins.
A pin on one end and a socket on the other. Use when connecting a breadboard hole to a component header pin.
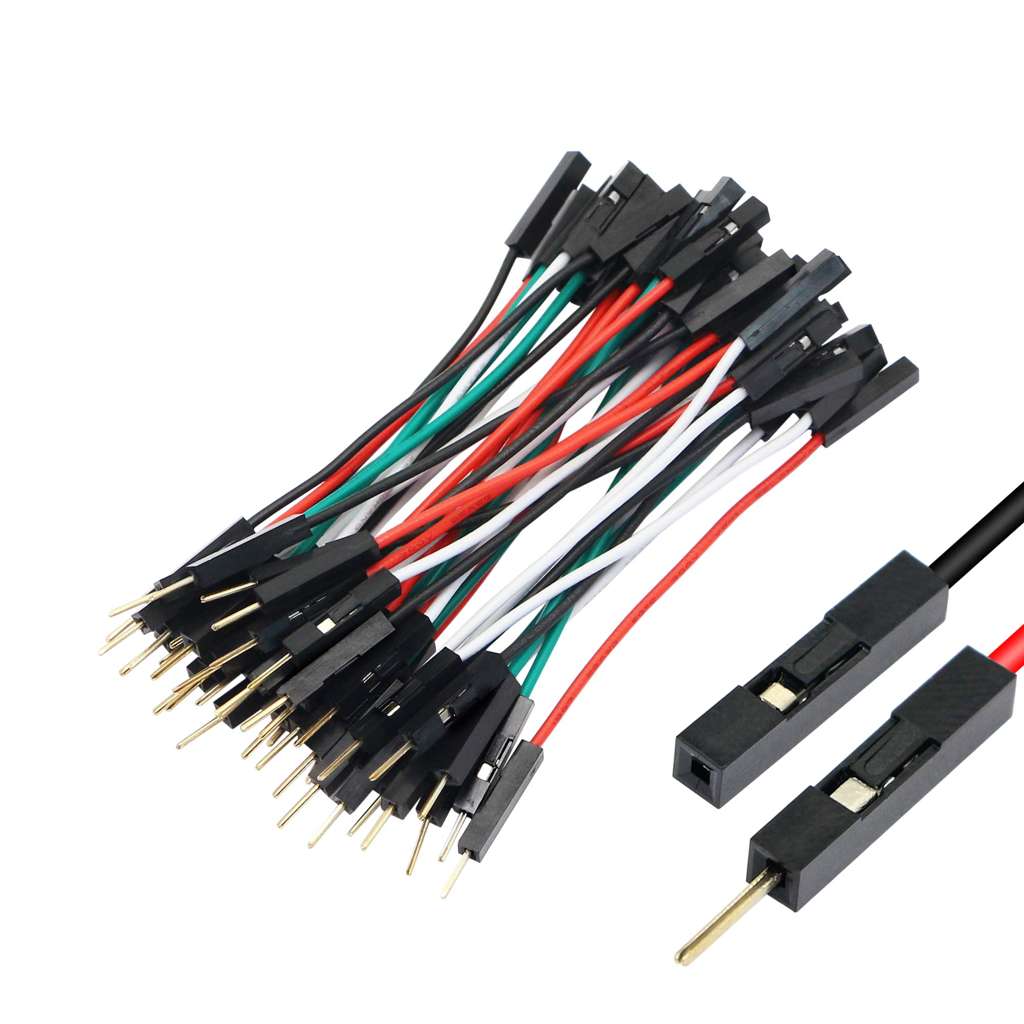
Keep wires organized by destination and never force a connector.
Follow the steps in order. Stop at every Tech Leader checkpoint. Never insert, remove, or change wiring while batteries are installed.
Attach the power switch securely in the designated slot at the back of the G-Lab Bot.
Bring the Bot and battery holder to the Heat Station. A Tech Leader will connect the battery holder's positive lead to the switch and connect the ground lead to a male Dupont wire. The Tech Leader will secure both connections with heat-shrink tubing.
After the Heat Station connections are complete and cool, glue the 18650 battery holder into its designated location on the Bot.
A Tech Leader will temporarily install two 18650 batteries. Test that the switch turns the circuit on and off, then use a multimeter to verify approximately 7.4V from the circuit. The Tech Leader removes the batteries after the test.
Peel the protective backing from the breadboard and press it firmly into the designated place on the Bot. Its adhesive backing holds it in place—no glue is needed.
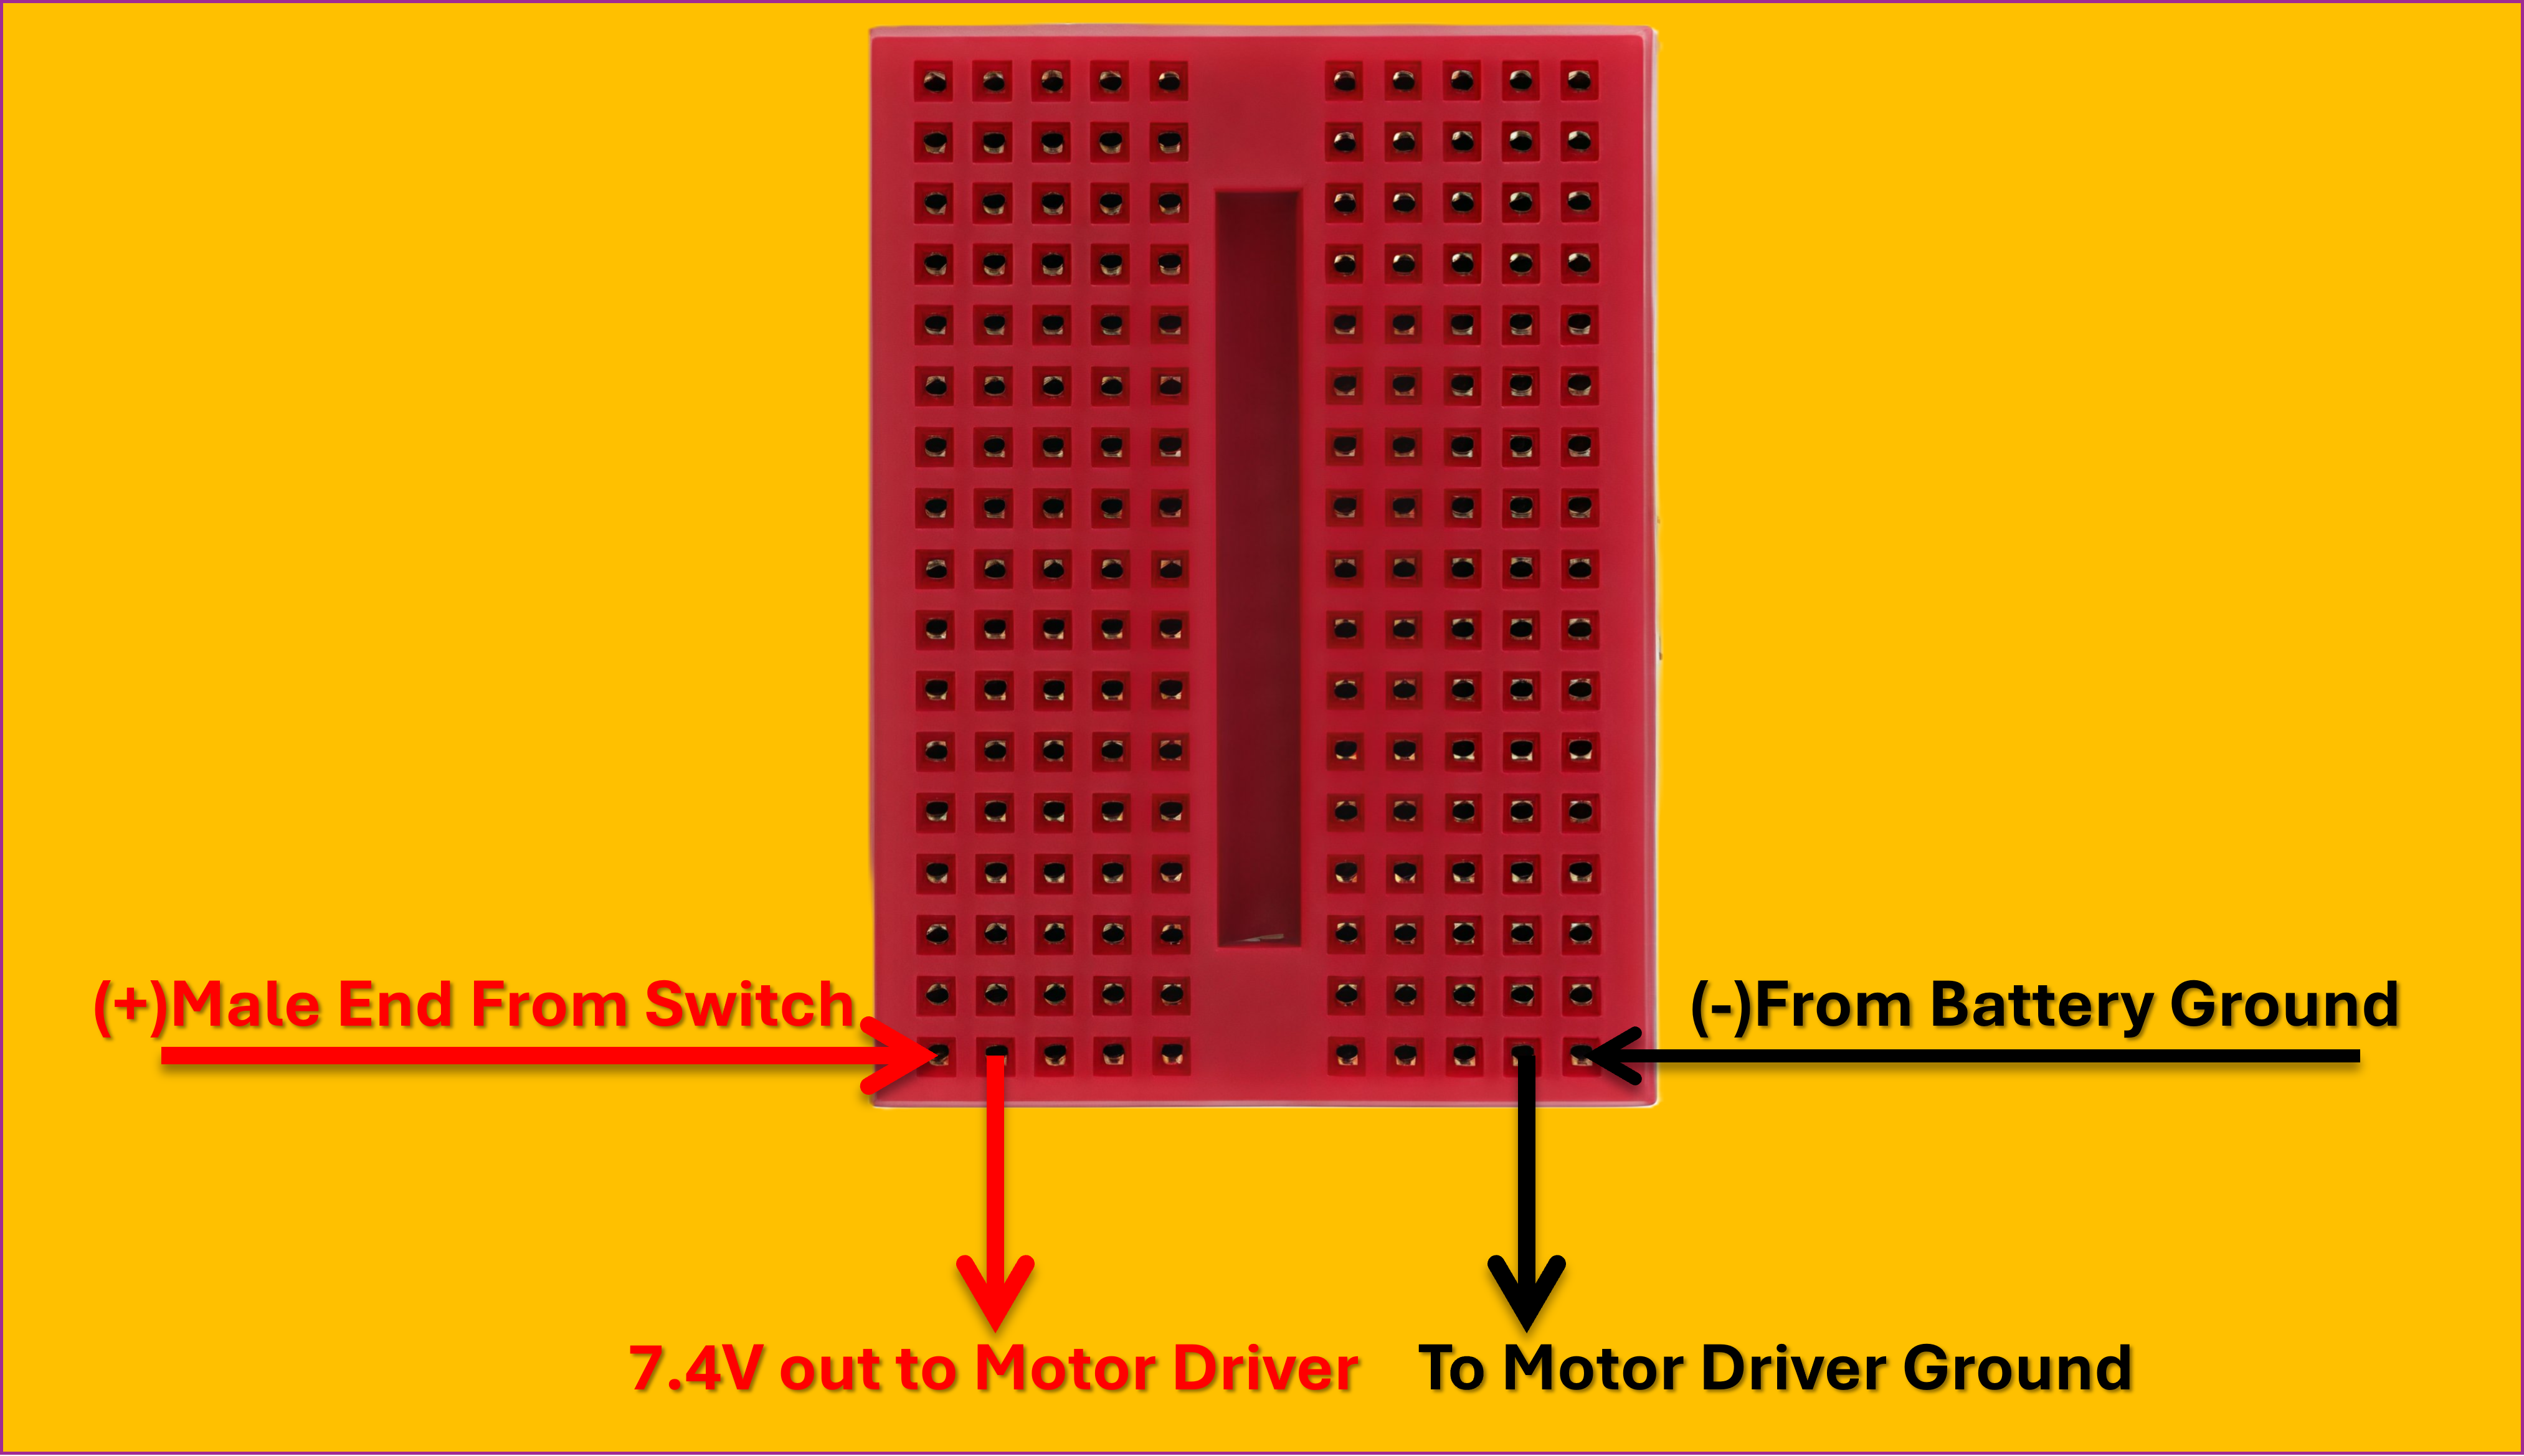
Follow the Establishing Rails illustration. Connect the switched positive lead to the positive rail and the battery ground male Dupont wire to the ground rail. Then route 7.4V and ground from those rails to the L298N Motor Driver.
Once rails are established, power can be routed wherever it is needed. Future add-ons—such as LED headlights and tail lights—can receive a suitable voltage through additional regulation or driver circuitry.
Slide the two TT Gear Motors into their designated slots. If needed, add only a small spot of glue to tighten the fit. Install the wheel caster in its designated mounting location so the Bot rolls and balances smoothly.
Use two M3 screws to mount the L298N Motor Driver. Add one small drop of glue in each mounting hole only if needed to secure the fit.
Wire the two motors, 7.4V input, ground input, and 5V output exactly as shown in the L298N illustration. Tighten screw terminals gently but firmly, then tug each wire lightly to confirm it is secure.
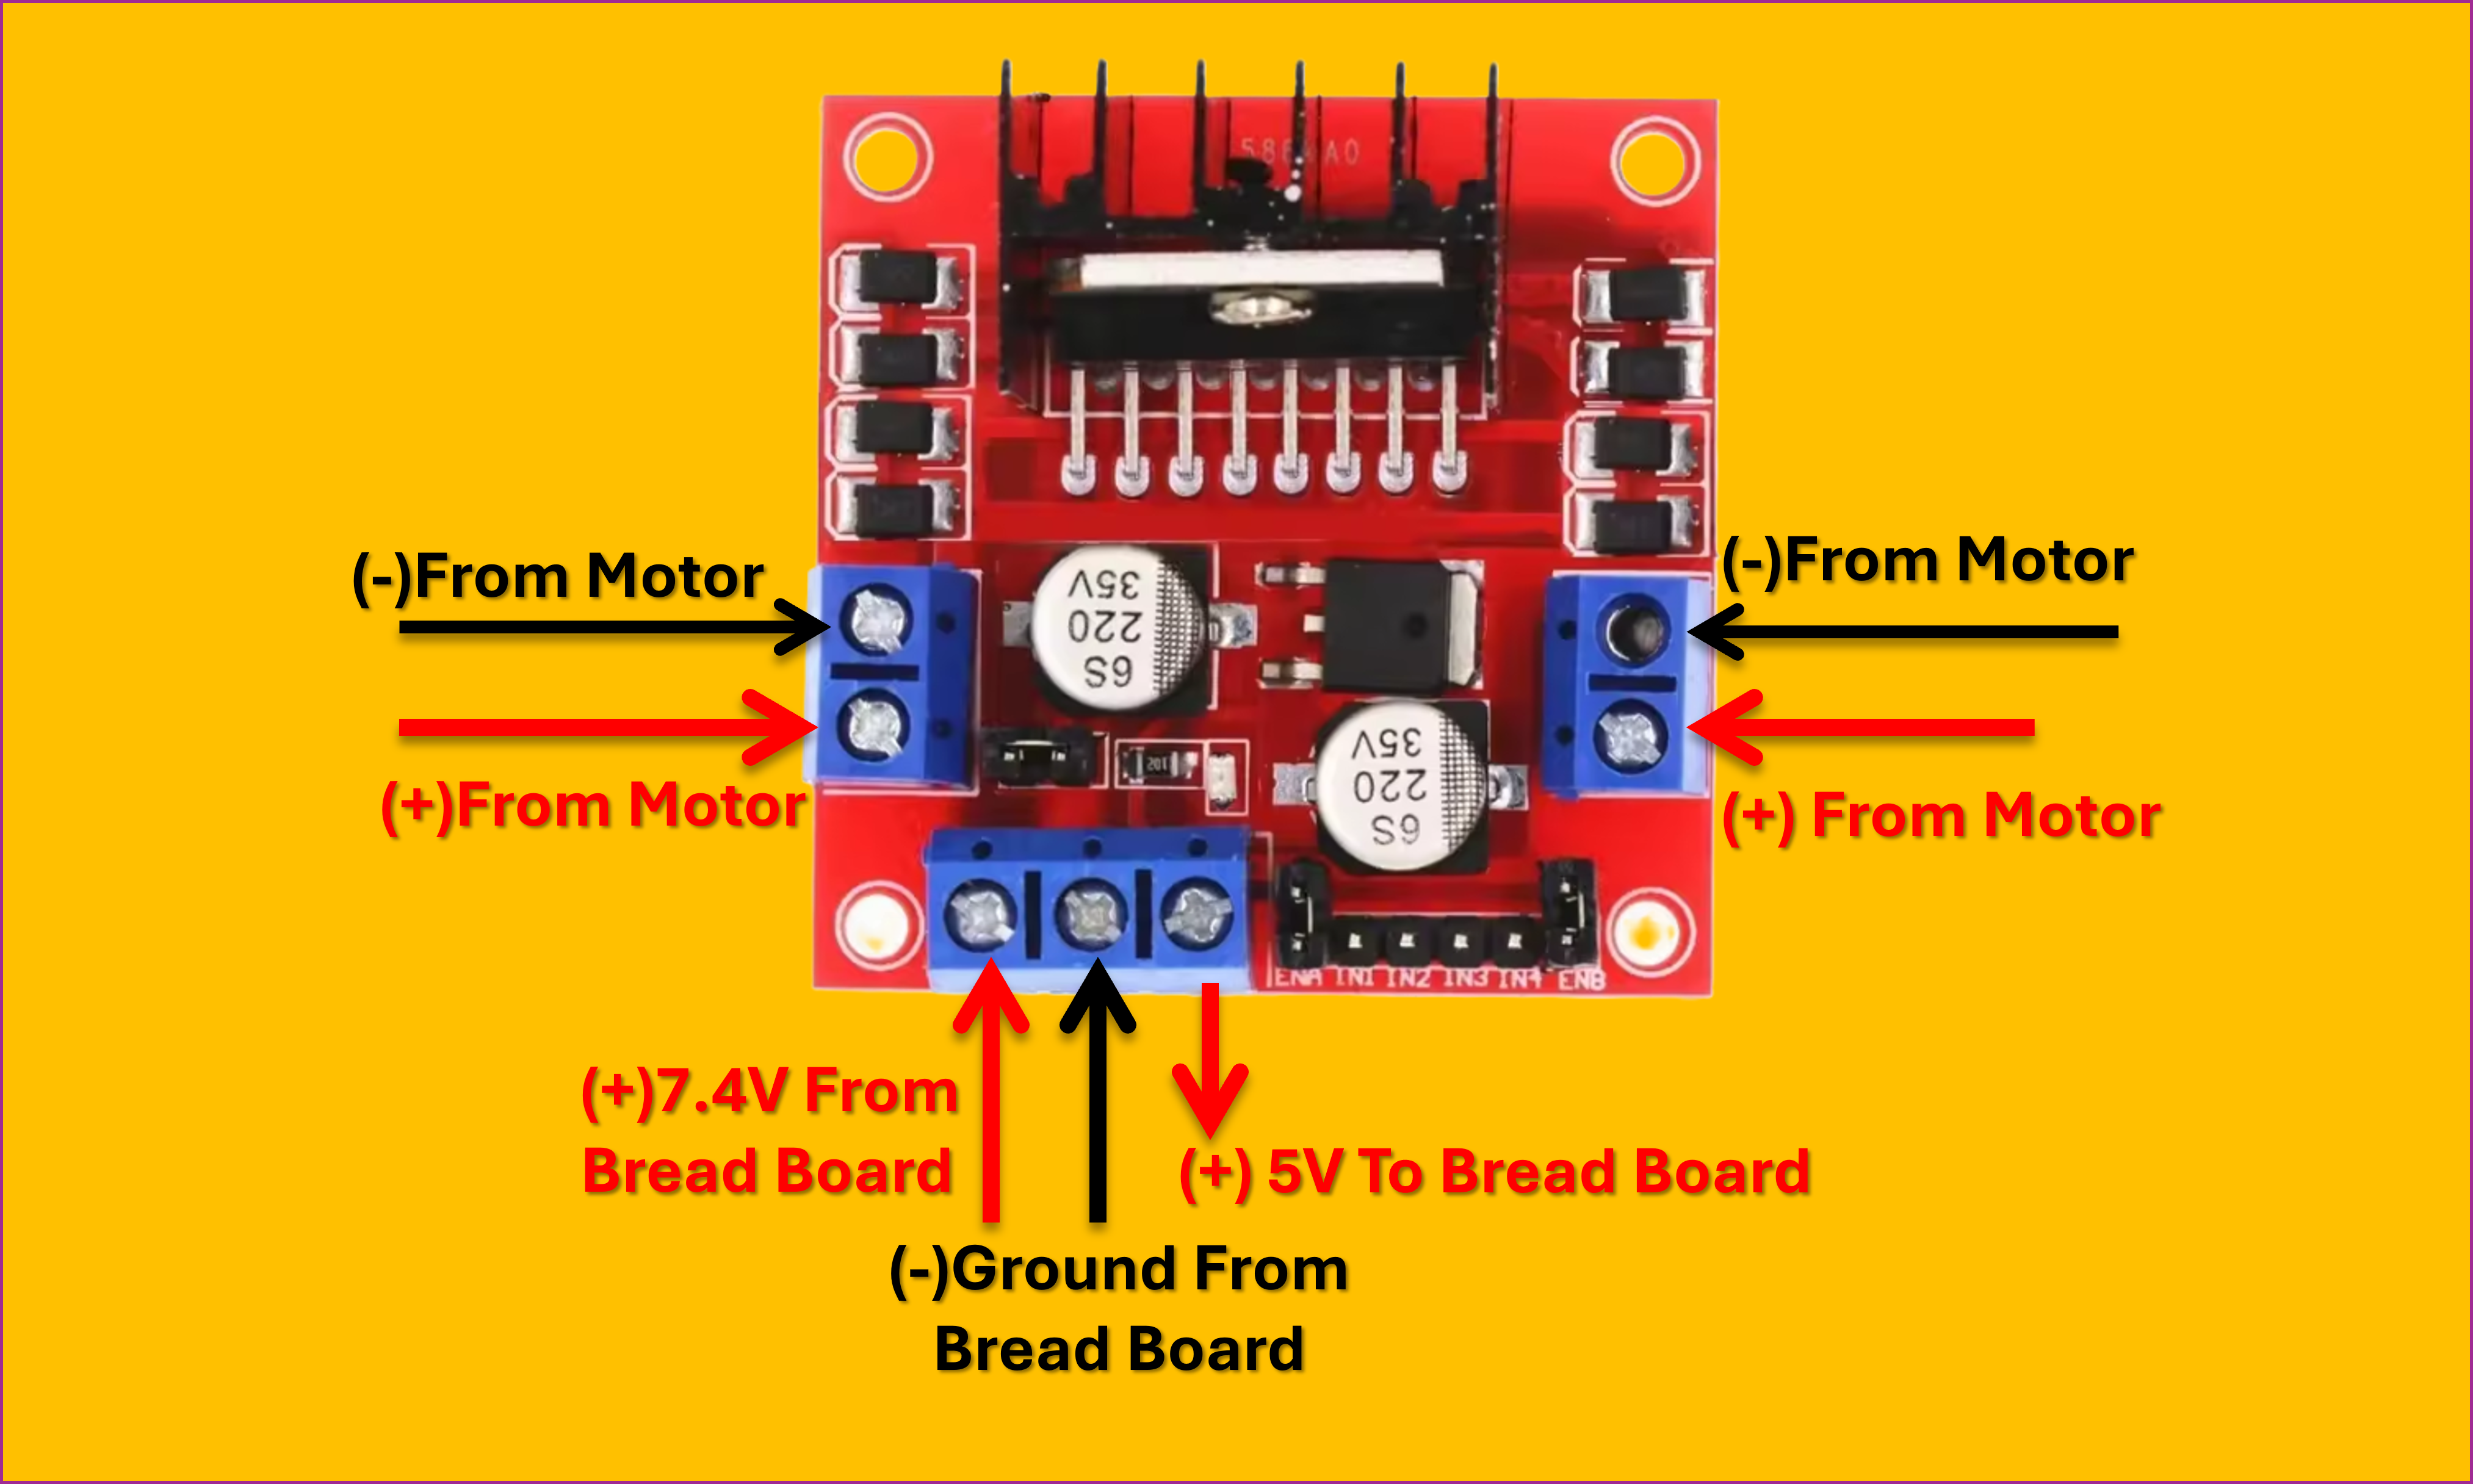
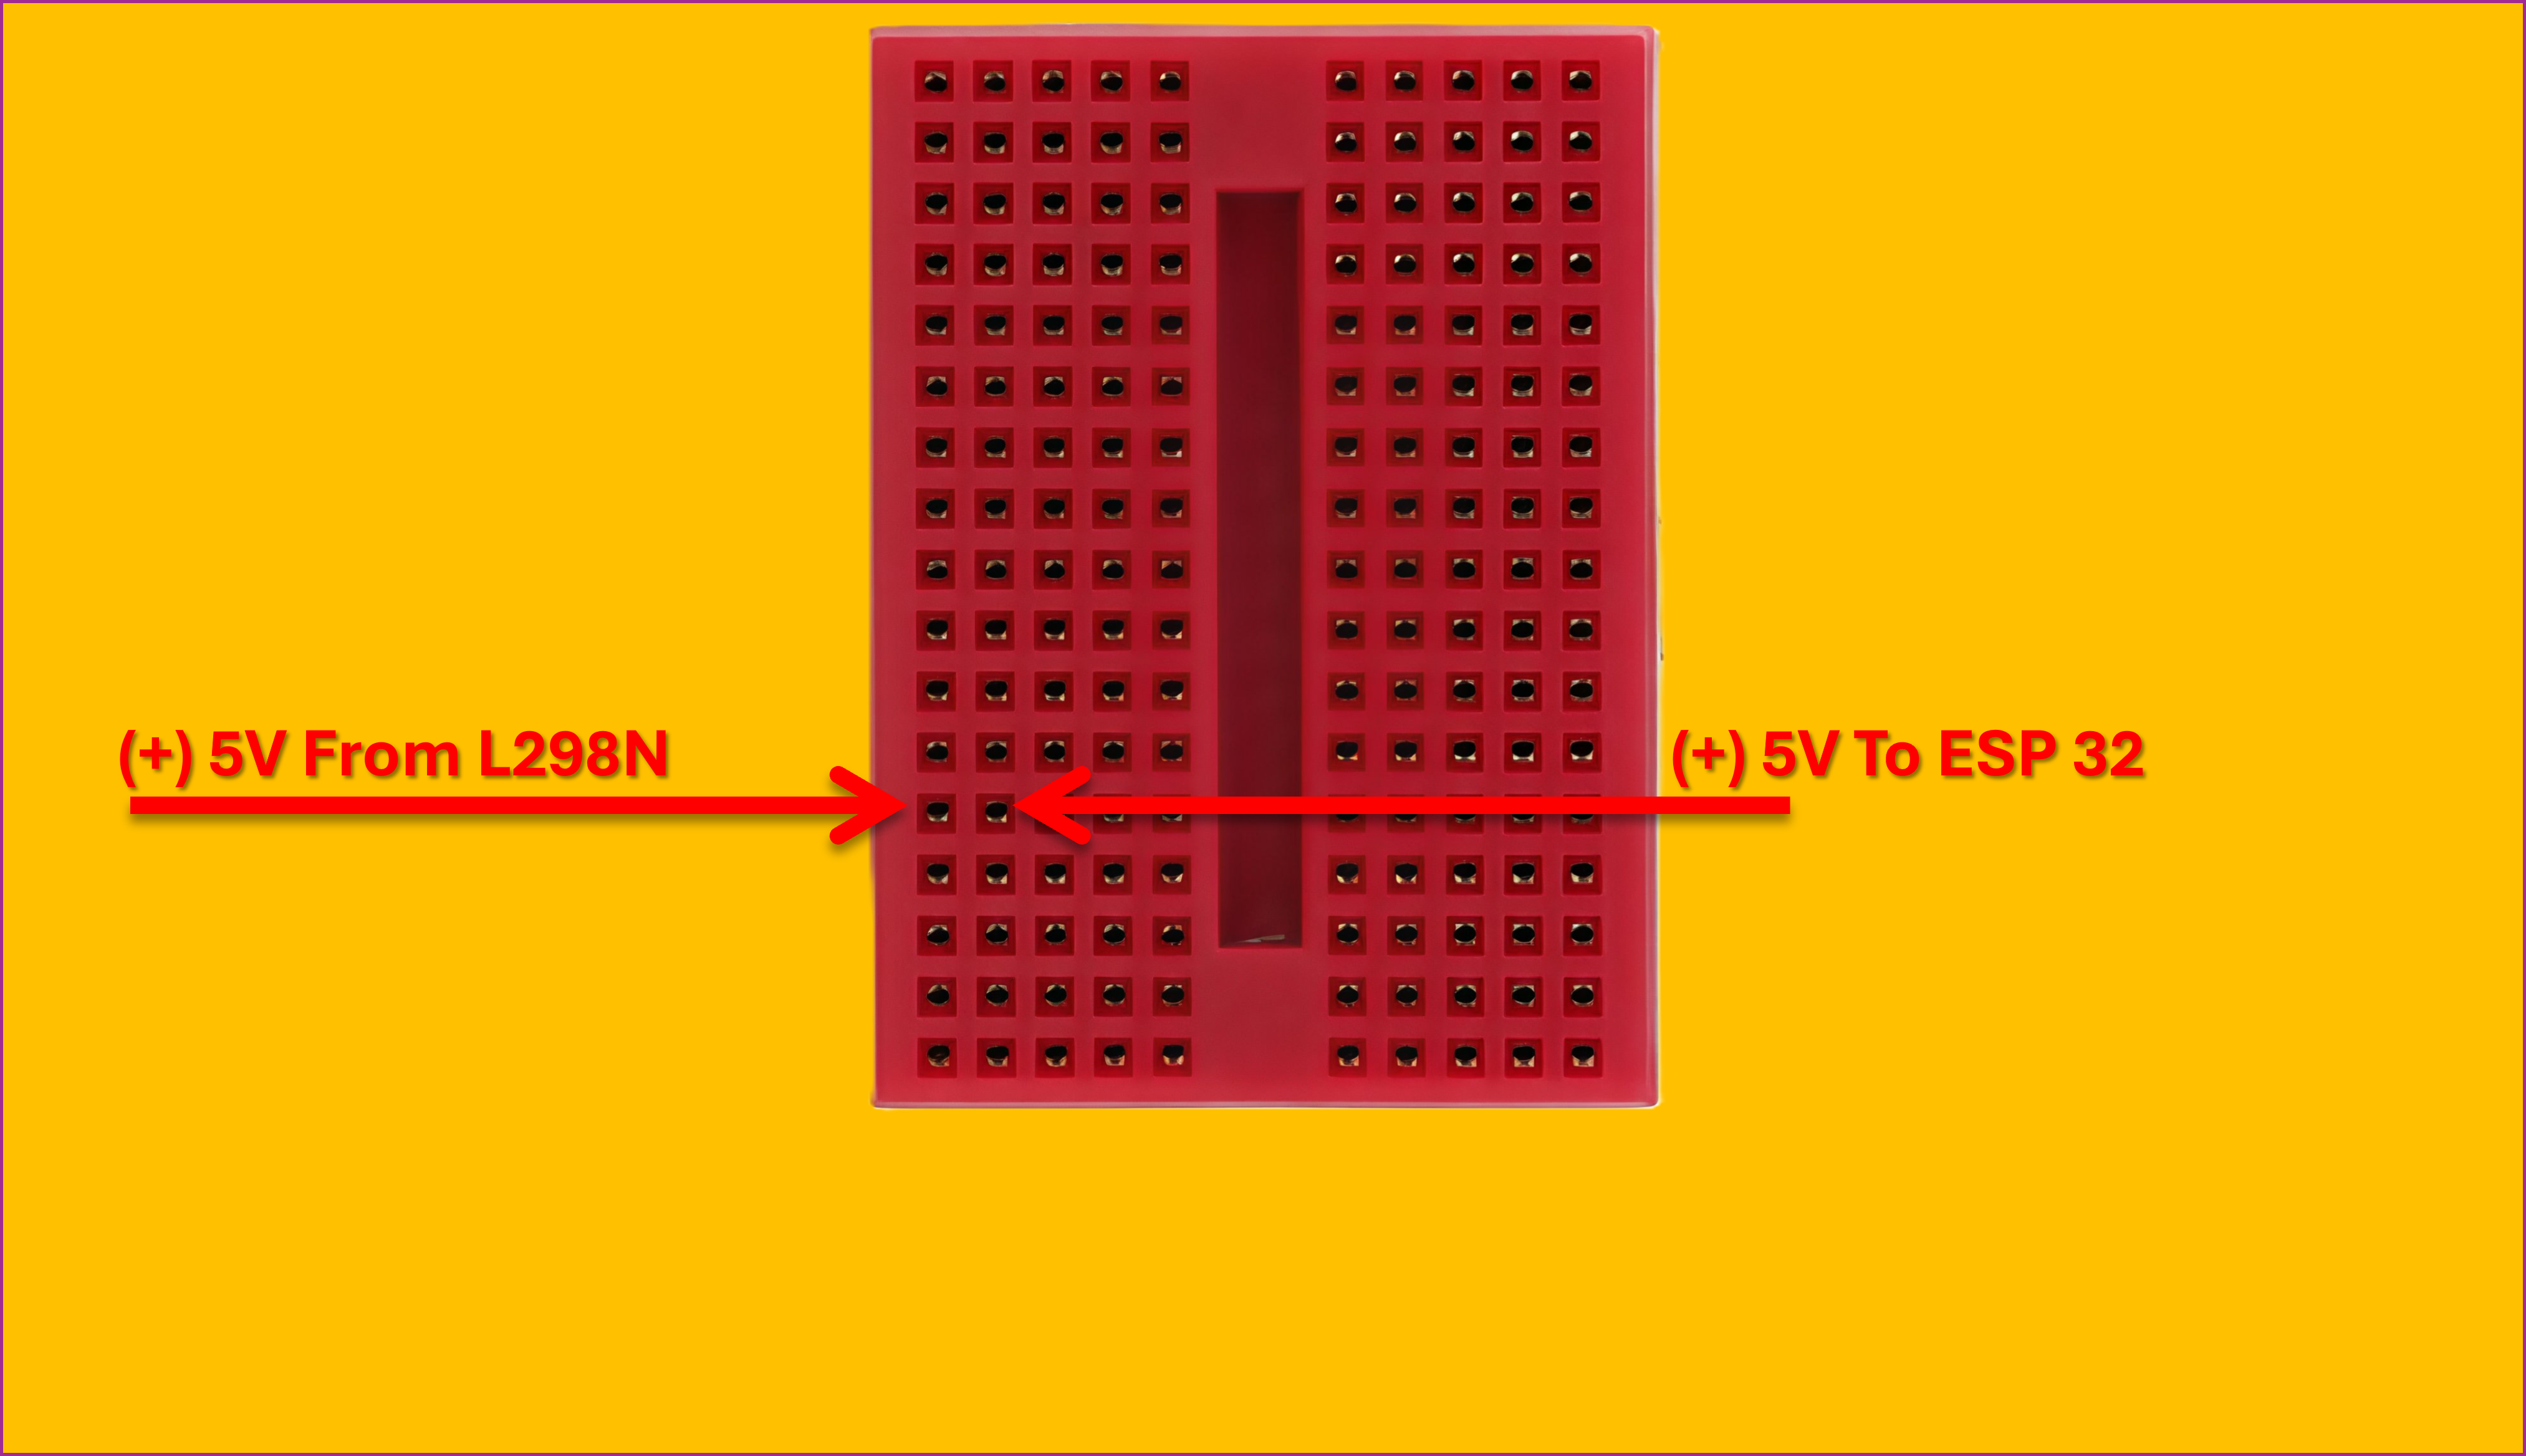
Connect the 5V output from the L298N Motor Driver to a second breadboard rail, as shown. This rail will power the ESP32. Keep it separate from the 7.4V rail.
Ask a Tech Leader if you need help. Use the exact pin map below.
IN1–IN4 control motor direction.
ENA and ENB control motor speed using PWM.
Connect the breadboard's 5V rail to the ESP32 5V pin. Then connect the breadboard's ground rail to an ESP32 GND pin. The ESP32 and L298N must share the same ground reference.
A Tech Leader will temporarily install the batteries and switch on the circuit. If everything is correct, you should see a red power light on both the L298N Motor Driver and the ESP32.
After the test, switch off and remove the batteries. You do not need them while uploading the sketch—the ESP32 receives power through the connected USB data cable.
A sketch is an Arduino program: a set of instructions that tells the ESP32 how to communicate with Dabble and control the motors.
Open the Arduino IDE. Insert the USB data cable into the ESP32 and the computer. Go to Tools → Port, select the connected COM port, and remember that port number for uploading.
This workshop's Dabble sketch requires the ESP32 Arduino Core version shown below.
Log in to the Genius Portal using the password provided by your Tech Leaders. Open the Genius Lab Sketch Library, then select the Bluetooth Controlled G-Lab Bot link.
A sketch is the complete program the Arduino IDE compiles and uploads to the ESP32. Copy all of the code from the Sketch Library and paste it into a new Arduino IDE sketch. Replace any starter text so the sketch contains the complete G-Lab Bot code.
Review the sketch and make sure it matches the Sketch Library. Then find the line near line 132:
Dabble.begin("ESP32_Vehicle");Dabble.begin("ESP32_VehicleJRA");Add your own initials immediately after Vehicle, inside the quotation marks. This creates a unique Bluetooth name and prevents conflicts with other Bots.
Double-check the selected board and remembered COM port, then click Upload. Wait for the IDE to finish compiling and uploading. If an error appears, read the message and troubleshoot with a Tech Leader—check the data cable, board selection, COM port, library, and ESP32 Core version.
Your Bot has hardware, power, and code. Now connect your phone or tablet and bring it to life.
The basic G-Lab Bot is only the beginning. Your established rails let you route power to carefully designed add-ons.
Add two white headlights with the Mod5 attachment and two red tail lights using separate 5V and 3.3V positive rails, four 100 Ω resistors, and a shared ground.
Open the Light Modification Guide →